HERO 2000 (ET-19) · Volume 10
Cheatsheet — Quick Reference
A dense, single-page reference distilled from Vols. 1–9. Every hard row carries the
source it traces to; nothing new is claimed here that is not established earlier in
the series. Where Heath’s catalogue settles a conflict, its figure is given;
otherwise both readings are shown as “X (spec sheet) / Y (secondary)” rather than
resolved. The authoritative primary for definitive numbers is the factory ET-19
Technical Manual; the deepest available technical anchor is the transcribed spec
sheet at hero.dsavage.net, checked against Heath’s catalogues.
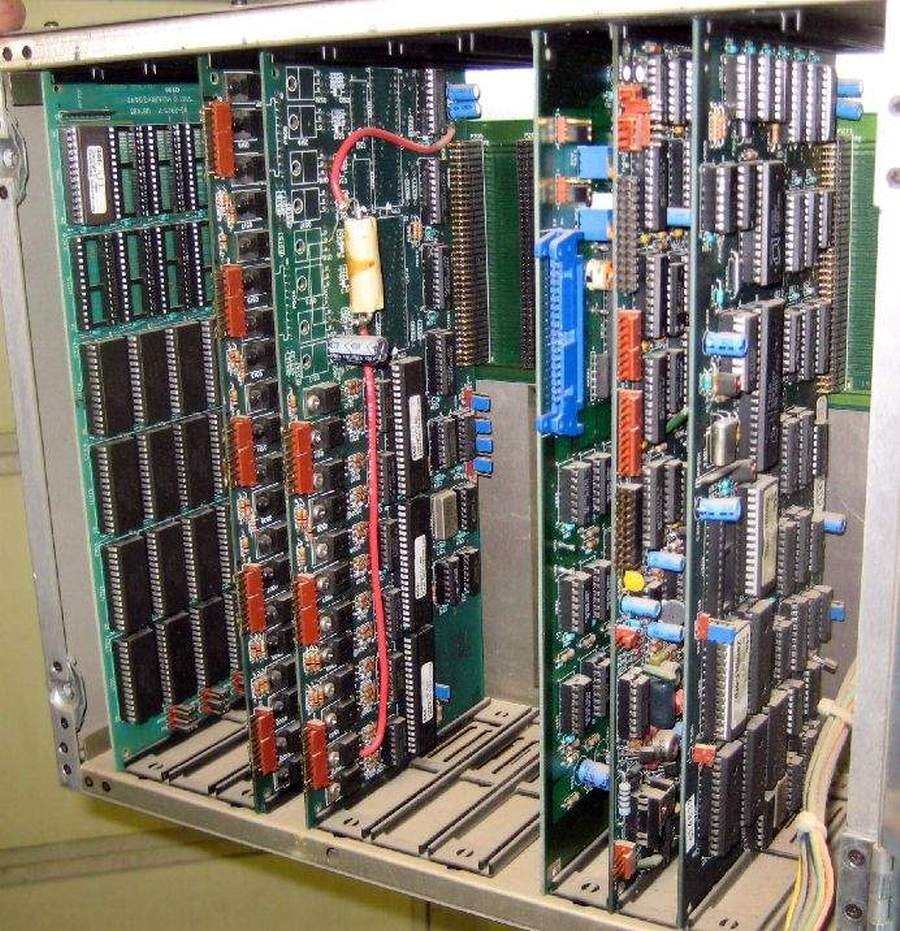
10.1 At a glance
Table 1 — At a glance
| Attribute | Value | Source |
|---|---|---|
| Name / model | HERO 2000 — kit ET-19 (no arm) / ETS-19 (arm); assembled EWS-19-35/-36 (1986), EWS-19-45/-46 (Fall 1987), ETW-19-A (Christmas 1987 on). “ET-19W” and “ET-2000” are not catalogue numbers | catalogue, Spring–Summer 1986; catalogue, Fall 1987; catalogue, Christmas 1987 |
| Maker | Heath Company / Heath-Zenith Educational Systems | CHM; Wikipedia |
| Year | 1986 (first catalogued Spring–Summer 1986; one source 1987) | catalogue, Spring–Summer 1986; robotworkshop |
| Price | $1,999.95 kit / $2,499.95 kit with arm / $4,499.95 assembled | catalogue, Spring–Summer 1986 |
| Units produced | ~3,000 (unverified) | Wikipedia |
| Line discontinued | 1995 | Wikipedia |
| Dimensions | 16.5 W × 22.5 L × 32.4 H inches | spec sheet |
| Weight | ~78 lb / 35 kg with arm | spec sheet |
10.2 Computing — multiprocessor
Table 2 — Computing — multiprocessor
| Item | Value | Source |
|---|---|---|
| Master CPU | Intel 8088, 16-bit — 5 MHz (spec sheet) / 4.77 MHz (secondary) | spec sheet; secondary |
| Slave processors | Intel 8042 UPIs (spec sheet) — one each for motor, sonar, RTC/keypad/display, comms, arm; + 2661 serial ctrl. (One secondary’s “Z-80” claim is contradicted by the spec sheet.) | spec sheet |
| Processor count | 8088 + “eleven 8-bit peripheral microprocessors” (catalogue, no mention of the arm) / ~6 base, 11 with arm (spec sheet) — see Vol. 2 | catalogue, Spring–Summer 1986; spec sheet |
| Backplane | Passive, up to 12 plug-in cards (CPU, memory, motor, arm, floppy, head-interface) | theoldrobots; Selectric |
10.3 Memory
Table 3 — Memory
| Item | Value | Source |
|---|---|---|
| RAM | 24 KB base, expandable to 576 KB with three optional memory boards (ETW-19-15, 192 KB each) | catalogue, Spring–Summer 1986 |
| ROM | 64 KB — monitor + HERO 2000 BASIC + demo/diagnostic/sensor routines | spec sheet; theoldrobots |
Exact address map: ET-19 Technical Manual (not reconstructed here).
10.4 Sensing — the 360° ring
Table 4 — Sensing — the 360° ring
| Sensor | Documented spec | Source |
|---|---|---|
| Sonar | 24 bearings, 15° apart (360°); 4 in (spec sheet) / 4.5 in (theoldrobots) to 10.5 ft (“up to 10 feet”, catalogue); 2 transducers | spec sheet; theoldrobots; catalogue, Spring–Summer 1986 |
| Light | 255 levels at 24 bearings, 15° apart | spec sheet |
| Sound | 255 levels | spec sheet |
| Temperature | +60°F to +90°F | spec sheet |
| Battery/voltage | Battery-condition sensing | spec sheet |
| Base rangefinder | Auxiliary sonar for low-lying objects in front | spec sheet; catalogue, Spring–Summer 1986 |
10.5 Drive & mobility
Table 5 — Drive & mobility
| Item | Value | Source |
|---|---|---|
| Drive | Two servo-driven side wheels on a four-wheel suspension; differential steering; eight speeds; turns in its own diameter | theoldrobots; catalogue, Spring–Summer 1986 |
| Pull capacity | Up to ~26 lb | theoldrobots |
| Drive wheel | Colson wheel | Selectric |
10.6 Arm (optional)
Table 6 — Arm (optional)
| Joint / spec | Range / value | Source |
|---|---|---|
| Shoulder / arm | 0–120° | spec sheet |
| Elbow | 0–180° | spec sheet |
| Wrist pivot | −179° to +180° | spec sheet |
| Axes | Five, plus a sixth from the rotating torso | catalogue, Spring–Summer 1986 |
| Payload | Up to 1 lb | spec sheet; catalogue, Spring–Summer 1986 |
| Gripper | Touch-sensing, nine grip-pressure levels | catalogue, Spring–Summer 1986 |
| Adds | Arm controller card (ETS-19-1) and its processor | catalogue, Spring–Summer 1986; spec sheet |
10.7 Speech
Table 7 — Speech
| Item | Value | Source |
|---|---|---|
| Mode | Direct text-to-speech (no phoneme hand-coding, unlike Votrax HERO 1/Jr) | spec sheet |
| Chip | SSI 263A (spec sheet) / “SPA-256” (secondaries) — likely chip vs board name, not settled | spec sheet; secondaries |
| Modes | Text-to-speech, phoneme, sound effects | spec sheet |
| Voice | 64 speech sounds; 4096 inflection levels; 16 rate and volume levels; four octaves | catalogue, Spring–Summer 1986 |
10.8 I/O, comms & programming
Table 8 — I/O, comms & programming
| Item | Value | Source |
|---|---|---|
| Serial | Two RS-232C (DCE) ports — terminal + printer; baud to 38,400 | spec sheet |
| Remote | ETS-19-35/-36 remote keyboard console, 75.43/75.67 MHz, 2 × 40 LCD, two-way, ~100 ft | catalogue, Spring–Summer 1986 |
| Status display | 16 head-mounted LED indicators (eight user-definable) + seven-digit data display | catalogue, Spring–Summer 1986 |
| Storage | Cassette port; floppy controller card; ETW-19-6 360K disk drive (Fall 1987) | catalogue, Spring–Summer 1986; Selectric; catalogue, Fall 1987 |
| Languages | HERO 2000 BASIC (full BASIC in ROM) + assembly; host development over RS-232 | spec sheet; CHM |
10.9 Power
Table 9 — Power
| Item | Value | Source |
|---|---|---|
| Battery | 12 V, 24 Ah (the spec sheet’s 14 Ah is contradicted) | catalogue, Spring–Summer 1986; theoldrobots |
| Runtime | Up to 4 h normal use; 6 h electronics only; up to 6 days in sleep mode | catalogue, Spring–Summer 1986 |
| Charger | 120 VAC; docking charger with angled rails | spec sheet; Selectric |
10.10 The HERO line, in one row each
Table 10 — The HERO line, in one row each
| Model | Distinguishing spec | Source |
|---|---|---|
| HERO 1 (ET-18) | 6808 @ 1 MHz, 4 KB RAM, 8 KB ROM, optional 5-axis arm + Votrax speech, 350° head | catalogue; HERO FAQ |
| HERO Jr (RT-1) | 6808 @ 1 MHz, 2 KB→24 KB RAM, built-in Votrax speech, fixed head, cartridges | catalogue; HERO FAQ |
| HERO 2000 (ET-19) | Intel 8088 + eleven 8-bit peripheral processors, 24 KB→576 KB RAM, 360° ring, text-to-speech | catalogue; spec sheet |
Sources
- ET-19 Technical Manual / Programming Manual (Heath/Zenith, 1986) — the authoritative primaries; cited as the consultable authority (not confirmed as free downloads). CHM catalogs them.
- HERO 2000 spec sheet —
hero.dsavage.net/robots/Hero2/Hero2_Specs.html, the transcribed factory spec sheet; the deepest technical anchor. - theoldrobots.com/hero2k.html — specs + photos.
- Wikipedia — “HERO (robot)”. selectric.org/hero2000 — firsthand restoration. robotworkshop, CHM, Bonhams — supporting.
- Heathkit catalogues, World Radio History: Spring–Summer 1986; Fall 1987; Christmas 1987; Spring 1988. Primary for model numbers, prices, battery, processor count and accessories.
The HERO line’s catalogue history is in the Robots History; the battery and mains-charger cautions are in Vol. 9. The model-number note is set out in Vol. 1.
Comments (0)